Xianjin Wu

I am at Huazhong University of Science and Technology (HUST). During my undergraduate studies, I was fortunate to be advised by Xiang Bai and Dingkang Liang.
My research interests lie in 3D scene understanding, spatial intelligence, and embodied AI, with a particular interest in machine learning systems (MLSys). I am interested in building intelligent systems that can understand the physical world and act efficiently within it.
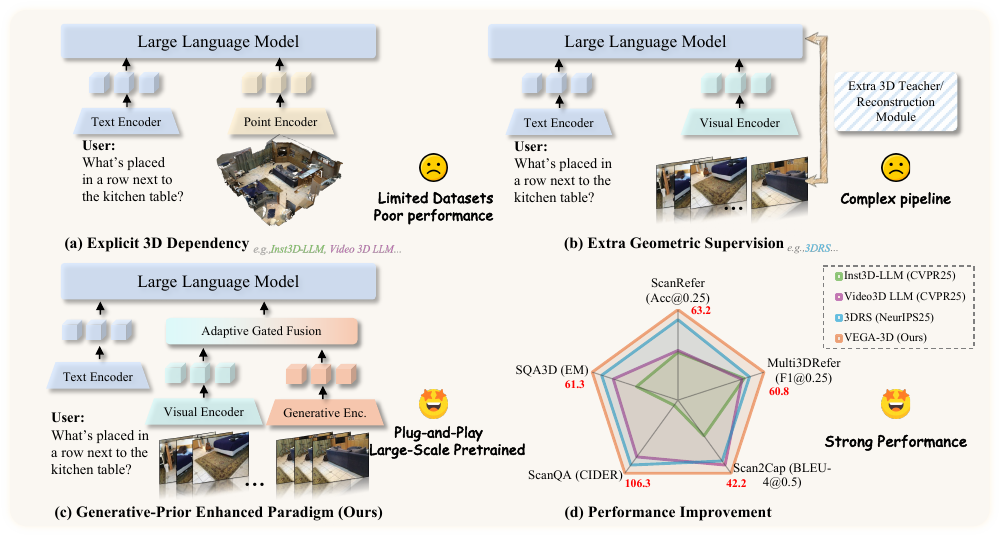
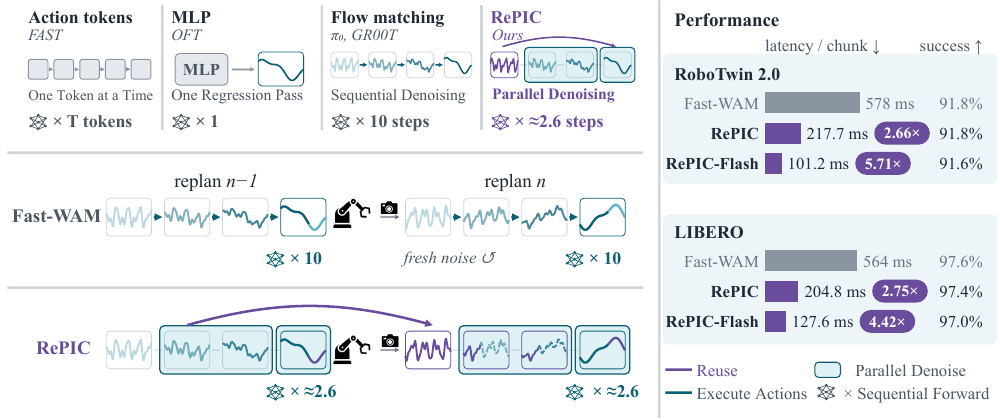
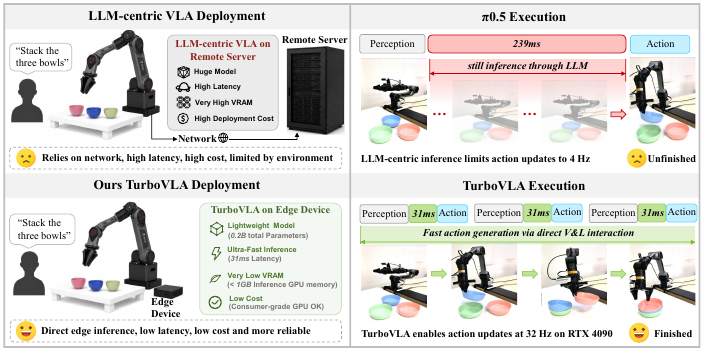
My recent work spans spatial understanding with VEGA-3D, real-time robotic manipulation with TurboVLA, and training-free policy acceleration with RePIC. I also work on multi-camera 3D perception and inference optimization through research and competitions.
I am currently a research intern at DiDi Voyager, and previously interned at Baidu.
Email · CV · Google Scholar · GitHub · ORCID
News
| Nov 2026 | Global Runner-Up (2/1,855 teams) — Team EVA won RMB 60,000 at the inaugural Robbyant Embodied AI Challenge on November 16, 2026. Tencent Technology (腾讯科技), Xinzhiyuan (新智元), and QbitAI (量子位) interviewed the team for their WeChat coverage. Read on WeChat.   |
|---|---|
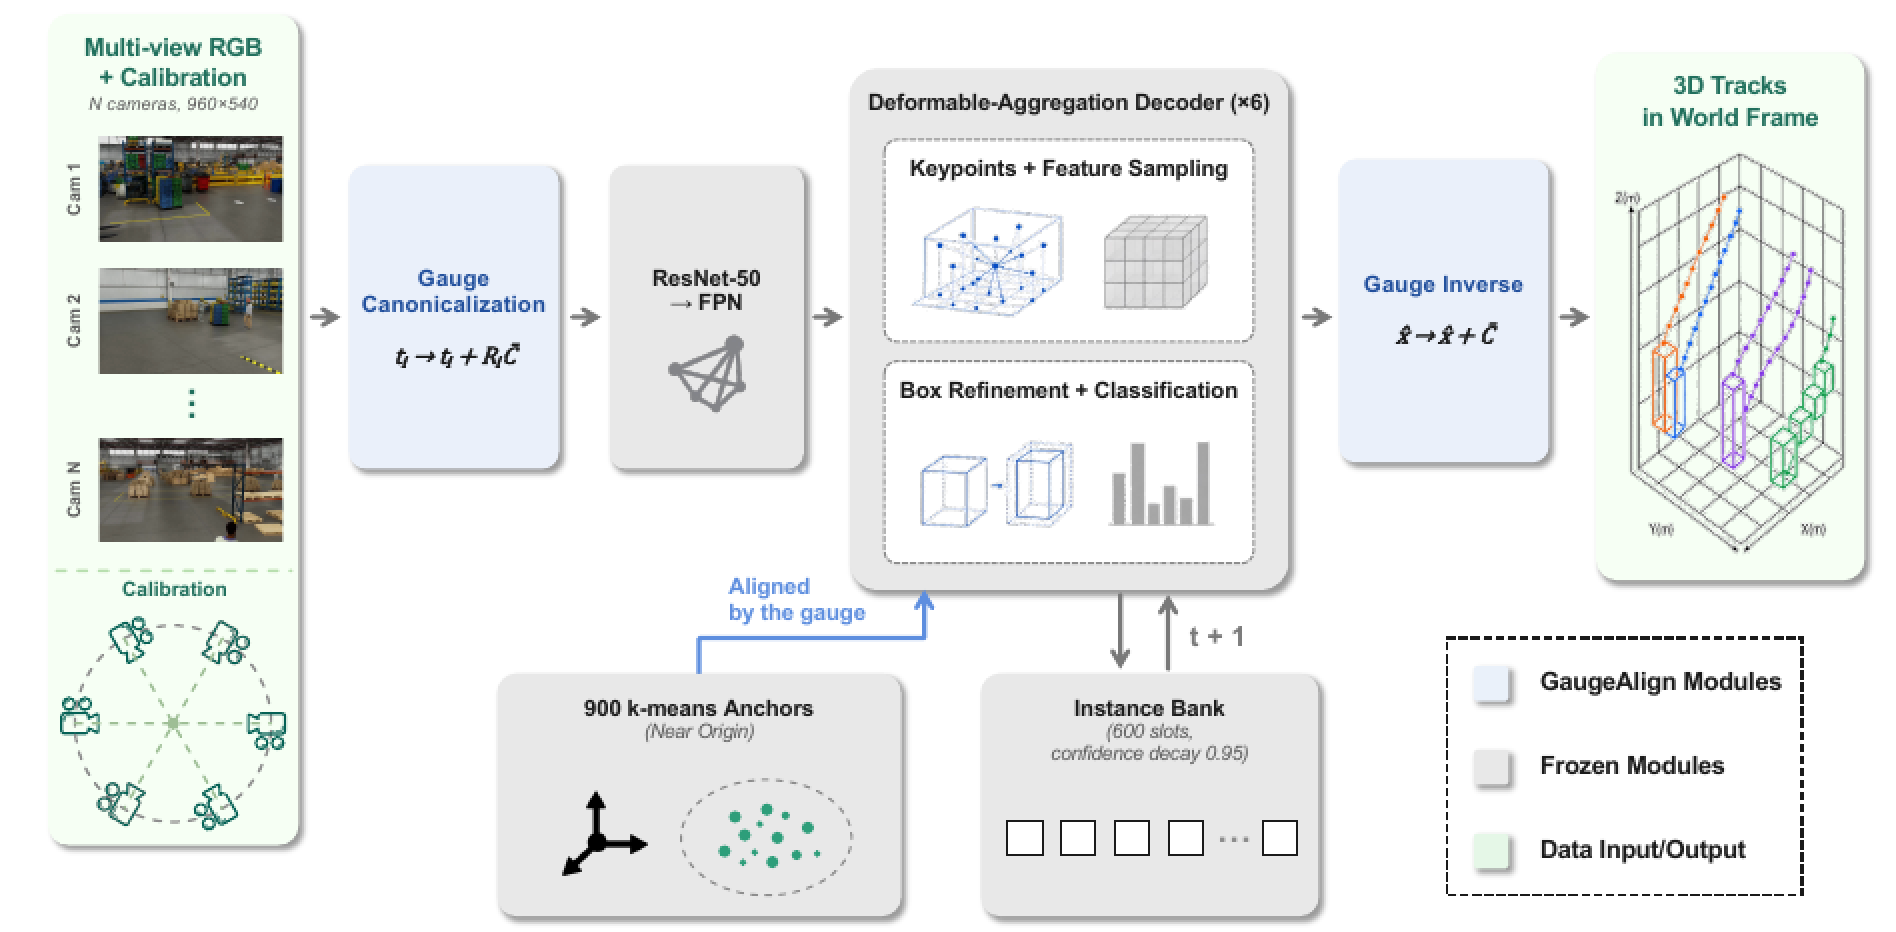
| Aug 2026 | Our team won 1st place in the AI City Challenge 2026, Track 1! GaugeAlign is available with code and our technical solution. |
| Jul 2026 | We released TurboVLA, a compact vision-language-action model for real-time robotic manipulation. |
| Jun 2026 | VEGA-3D was accepted to ECCV 2026! |
Selected Publications
Honors & awards
Kaggle Expert (3,590 of 225,021) · HyperbolicCurve
2026
- Global Runner-Up (2/1,855 teams) — Team EVA won RMB 60,000 at the inaugural Robbyant Embodied AI Challenge on November 16, 2026. Tencent Technology (腾讯科技), Xinzhiyuan (新智元), and QbitAI (量子位) interviewed the team for their WeChat coverage. Read on WeChat.
- 2nd Place — Learn2Design 2026 Challenge · NeurIPS 2026 Competition Track: Automated Design of Gravitational-Wave Detectors. Challenge repository. Prize: €6,000.
- 1st Place — AI City Challenge, Track 1 · ECCV Workshop 2026: Multi-Camera 3D Perception. Winning solution: GaugeAlign. Shared by NVIDIA AI on X.
- Grand Final Champion — SOAR Sparse Operator Acceleration Competition. Optimized MiniCPM-SALA inference with SGLang, including NVFP4 quantization, attention kernels, and speculative decoding. Certificate. Prize: US$70,000. Organizers & partners:

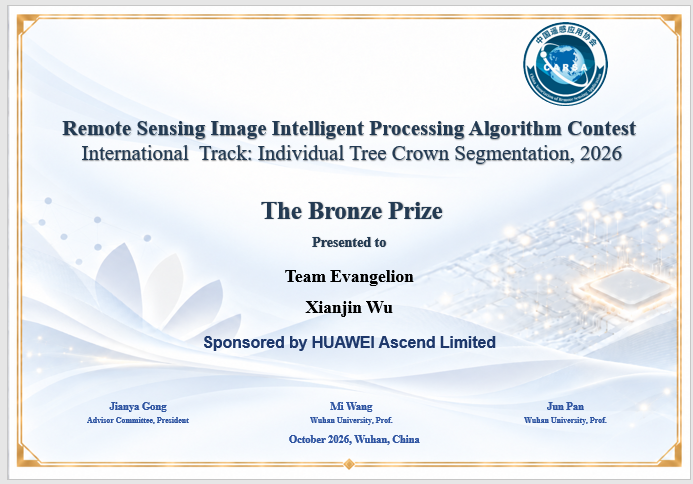
- Bronze Prize — RSIPAC, International Track: Individual Tree Crown Segmentation. Certificate.
- 10th Place — MangoTV AI Challenge: Multi-View Generation.
- Second Prize — ICME Grand Challenge, Track 2: Fine-Grained Severity Grading for High-Precision Manufacturing. Certificate.
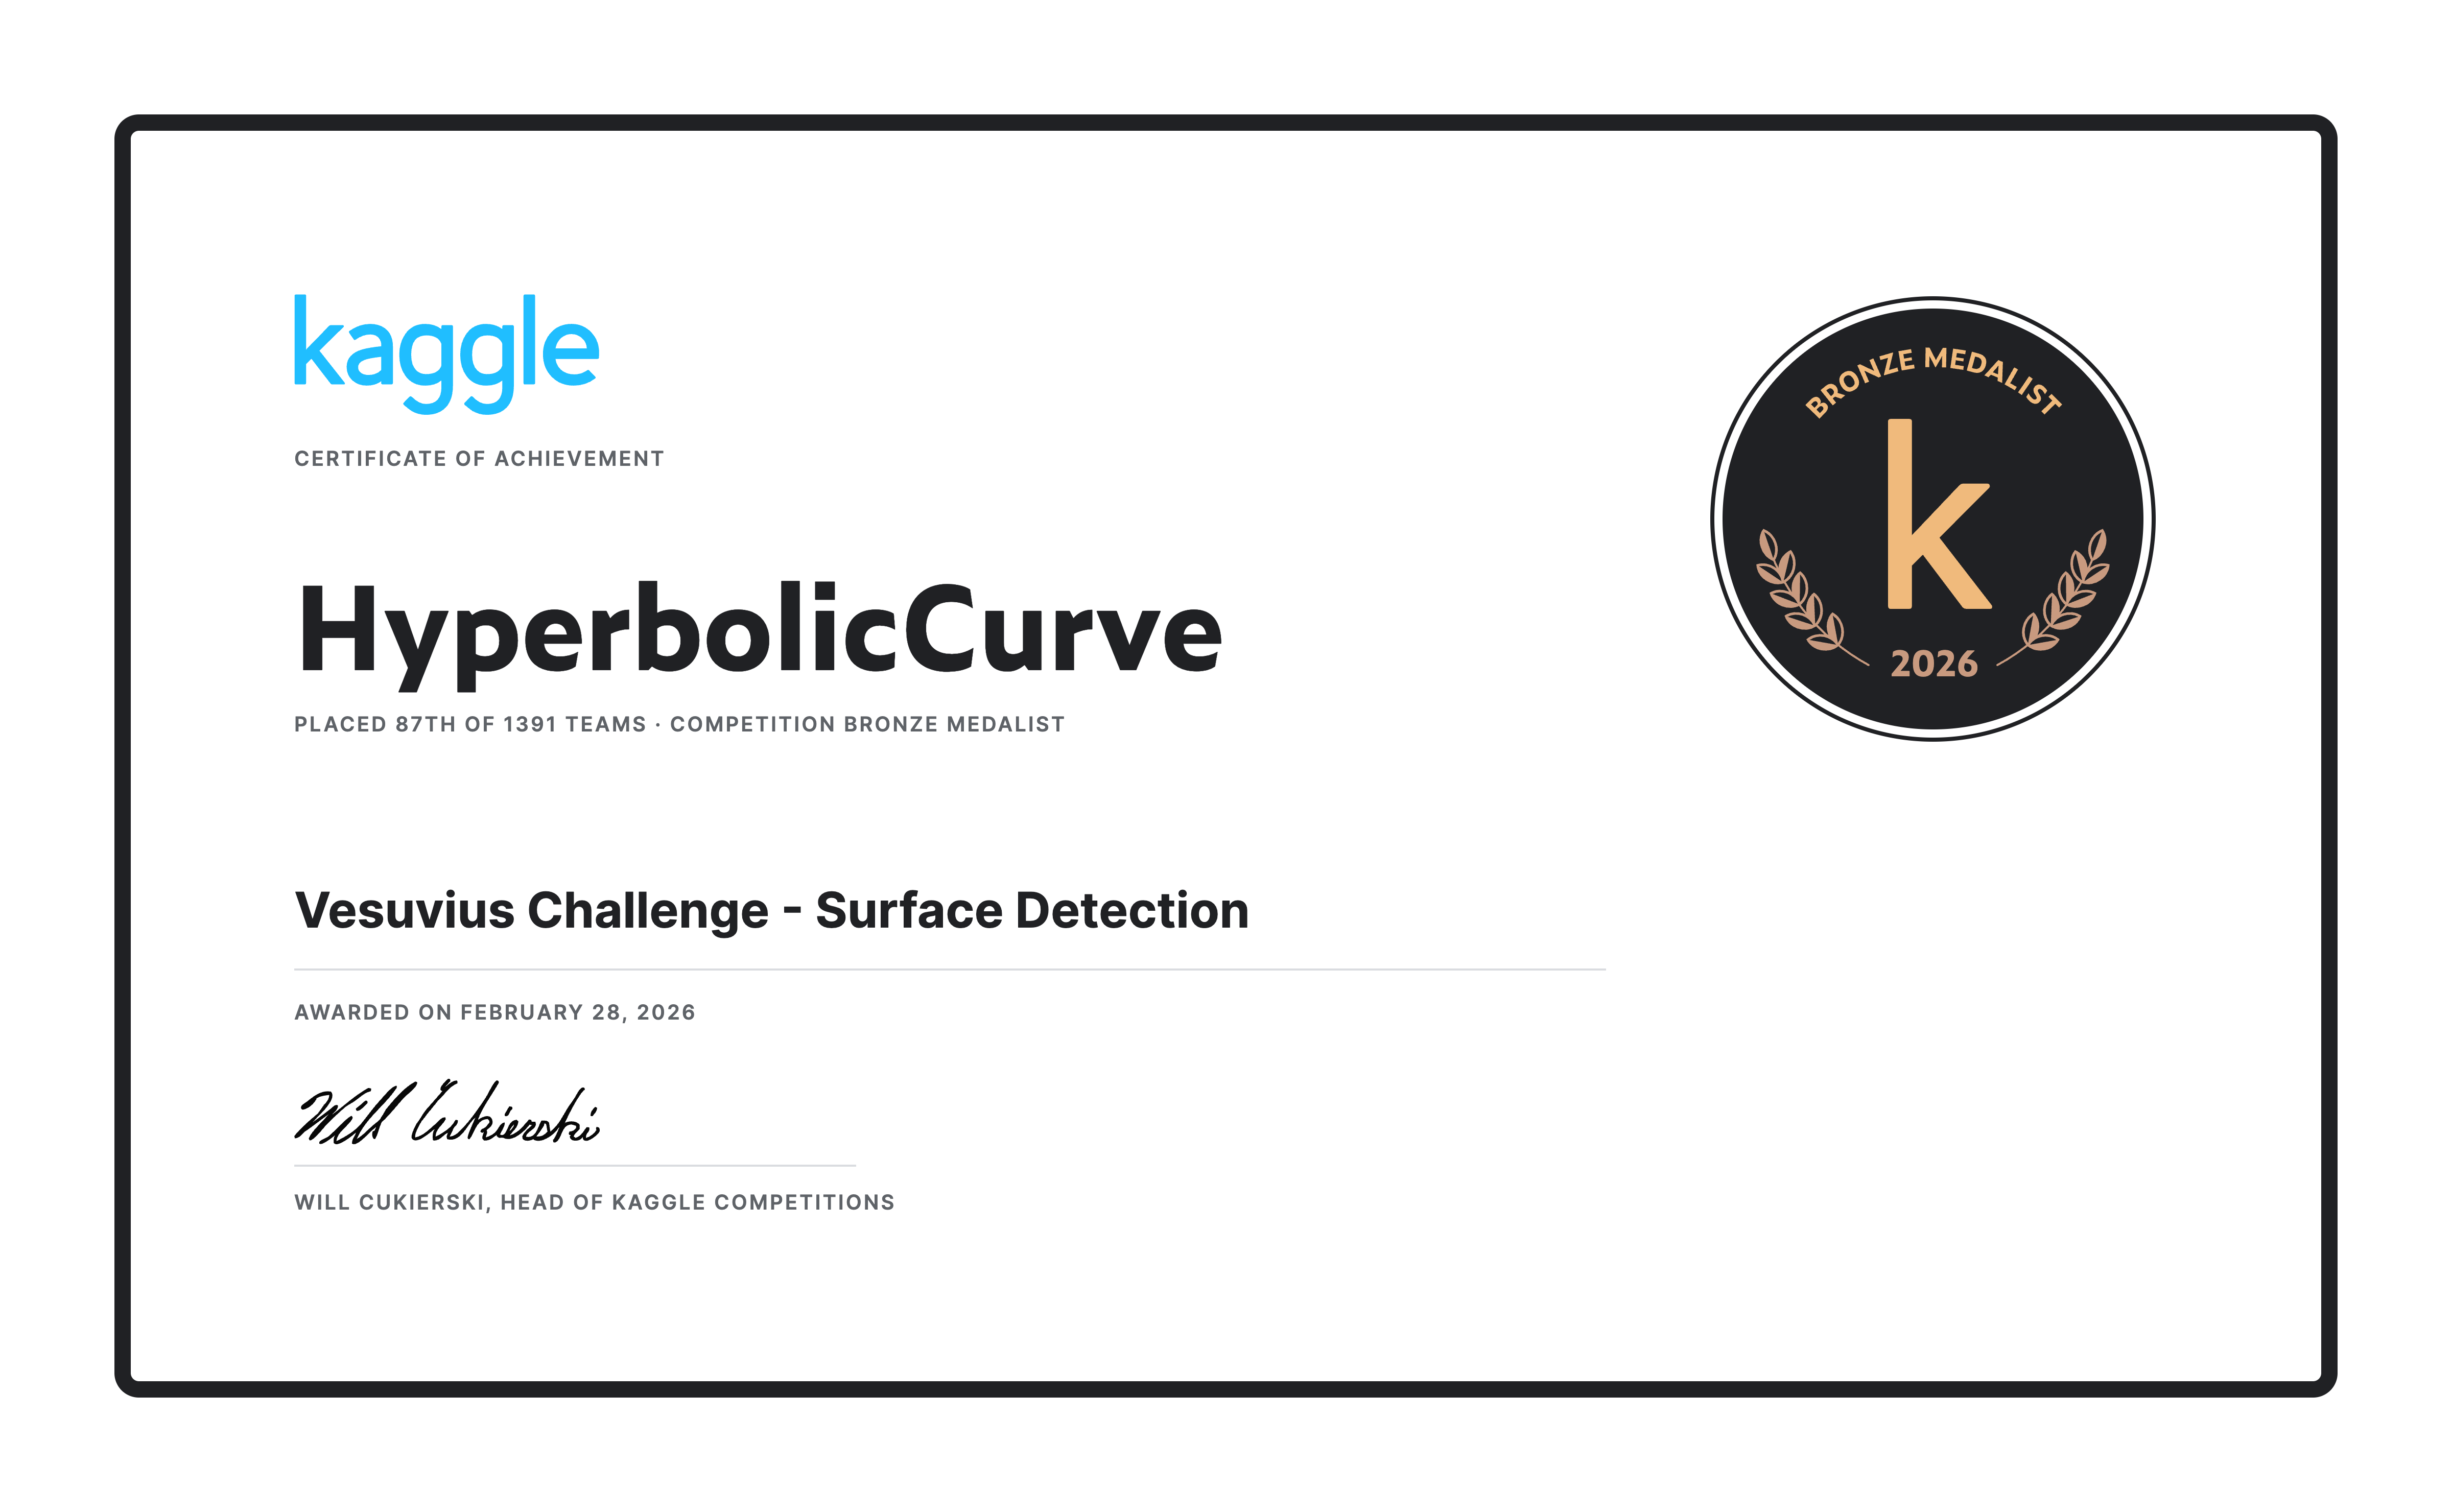
- Bronze Medal · 87 / 1,391 teams — Kaggle Vesuvius Challenge: Surface Detection. Certificate.
2025
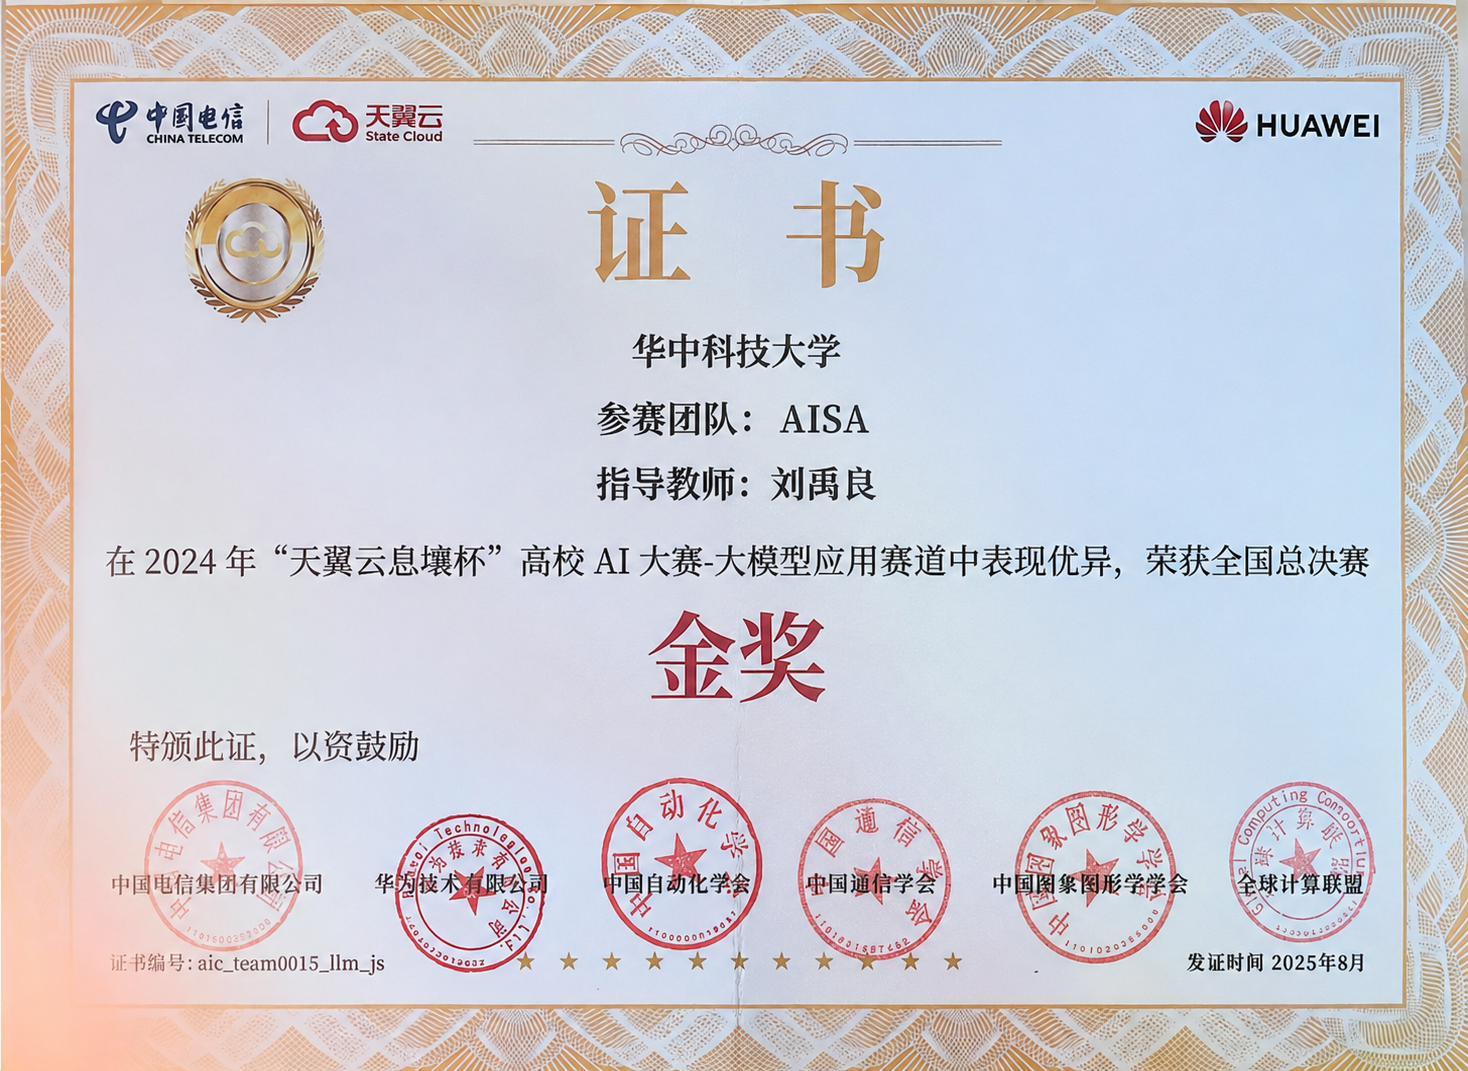
- National Final Gold Award — Tianyi Cloud “Xirang Cup” University AI Competition, Large Model Application Track. Certificate. Prize: RMB 200,000.
- 4th Place — Global Wheat Full Semantic Segmentation Competition. Certificate.
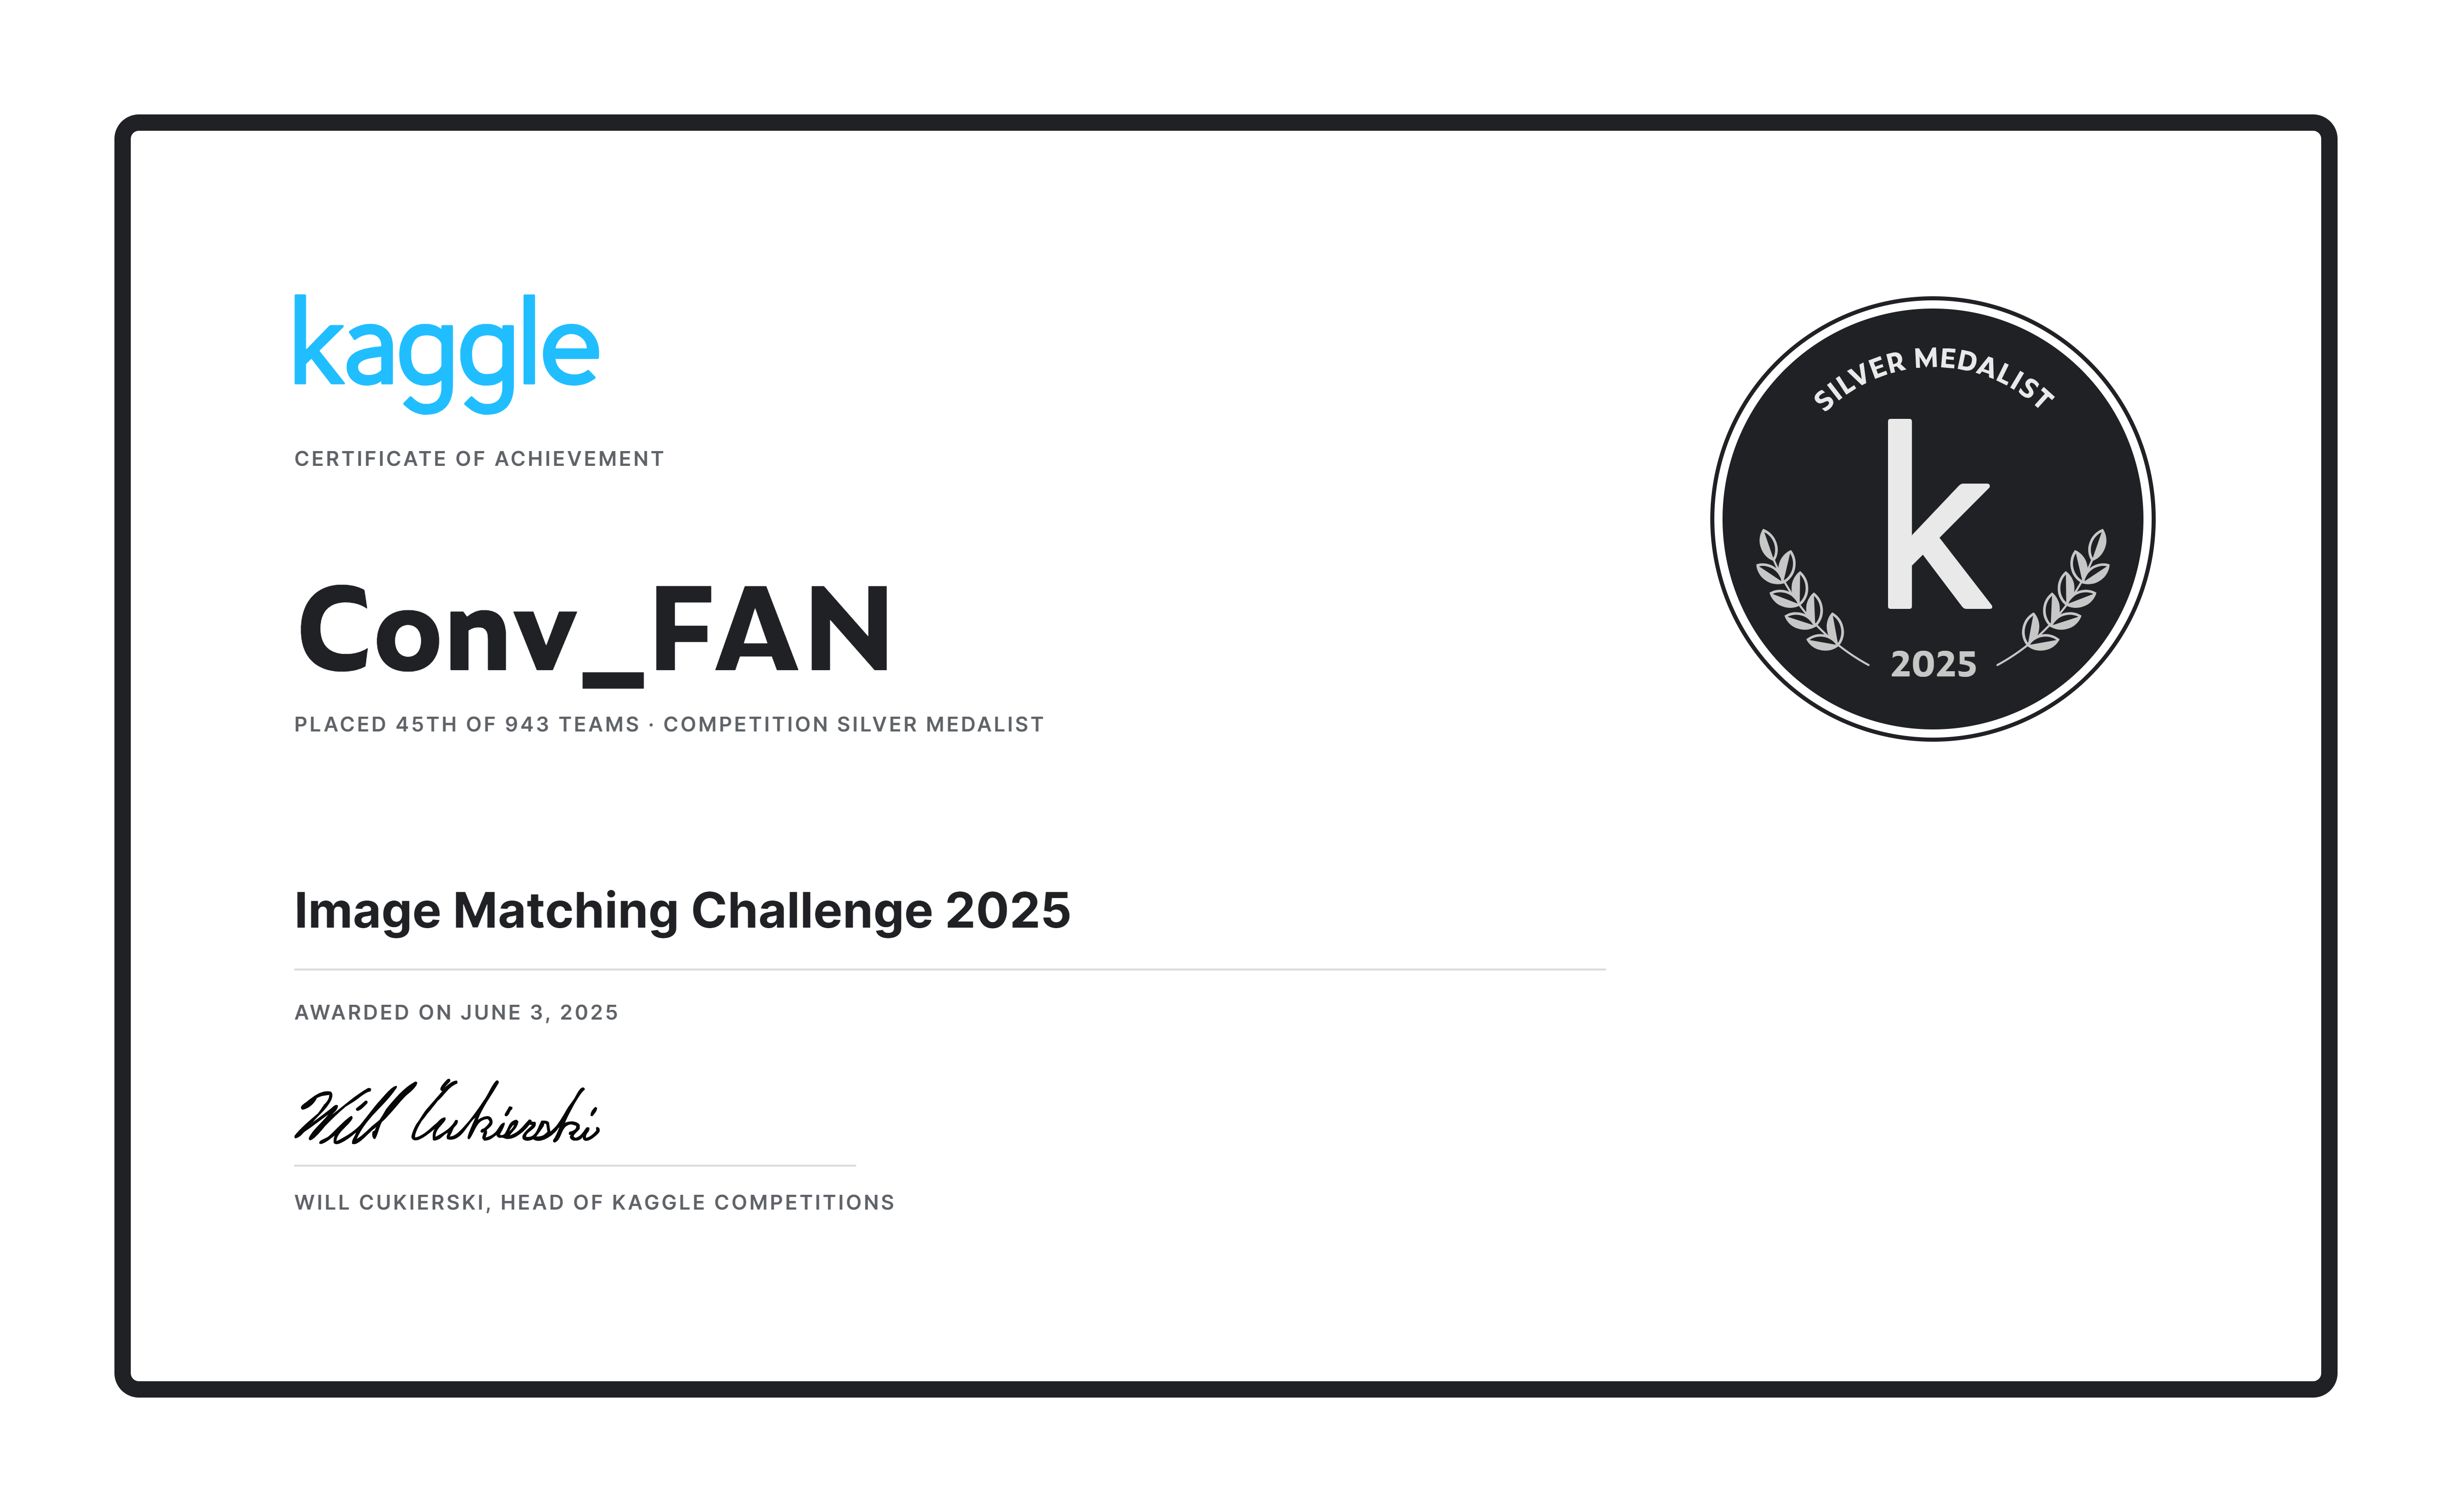
- Silver Medal · 45 / 943 teams — Kaggle Image Matching Challenge. Certificate.
Industrial Experience

DiDi Voyager Research Intern
August 2026 – Present
Mentors: Xuesong Chen and Shaoshuai Shi.
Baidu Research Intern
August 2025 – April 2026
Mentors: Kui Xia and Yumeng Zhang.
Education
Huazhong University of Science and Technology
B.Eng. in Artificial Intelligence
Sep 2022 - Jun 2026
Wuhan, China
Academic service
Reviewer: PR, ECCV, ICLR.